---
title: "Spatial capture-recapture from scratch"
description: "Spatial capture-recapture in base R: a from-scratch SCR likelihood with latent activity centres, and why a non-spatial estimate cannot give you a density."
date: "2026-05-20 11:00"
date-modified: "2026-10-07"
categories: [R, capture-recapture, spatial, abundance, ecology tutorial]
image: thumbnail.png
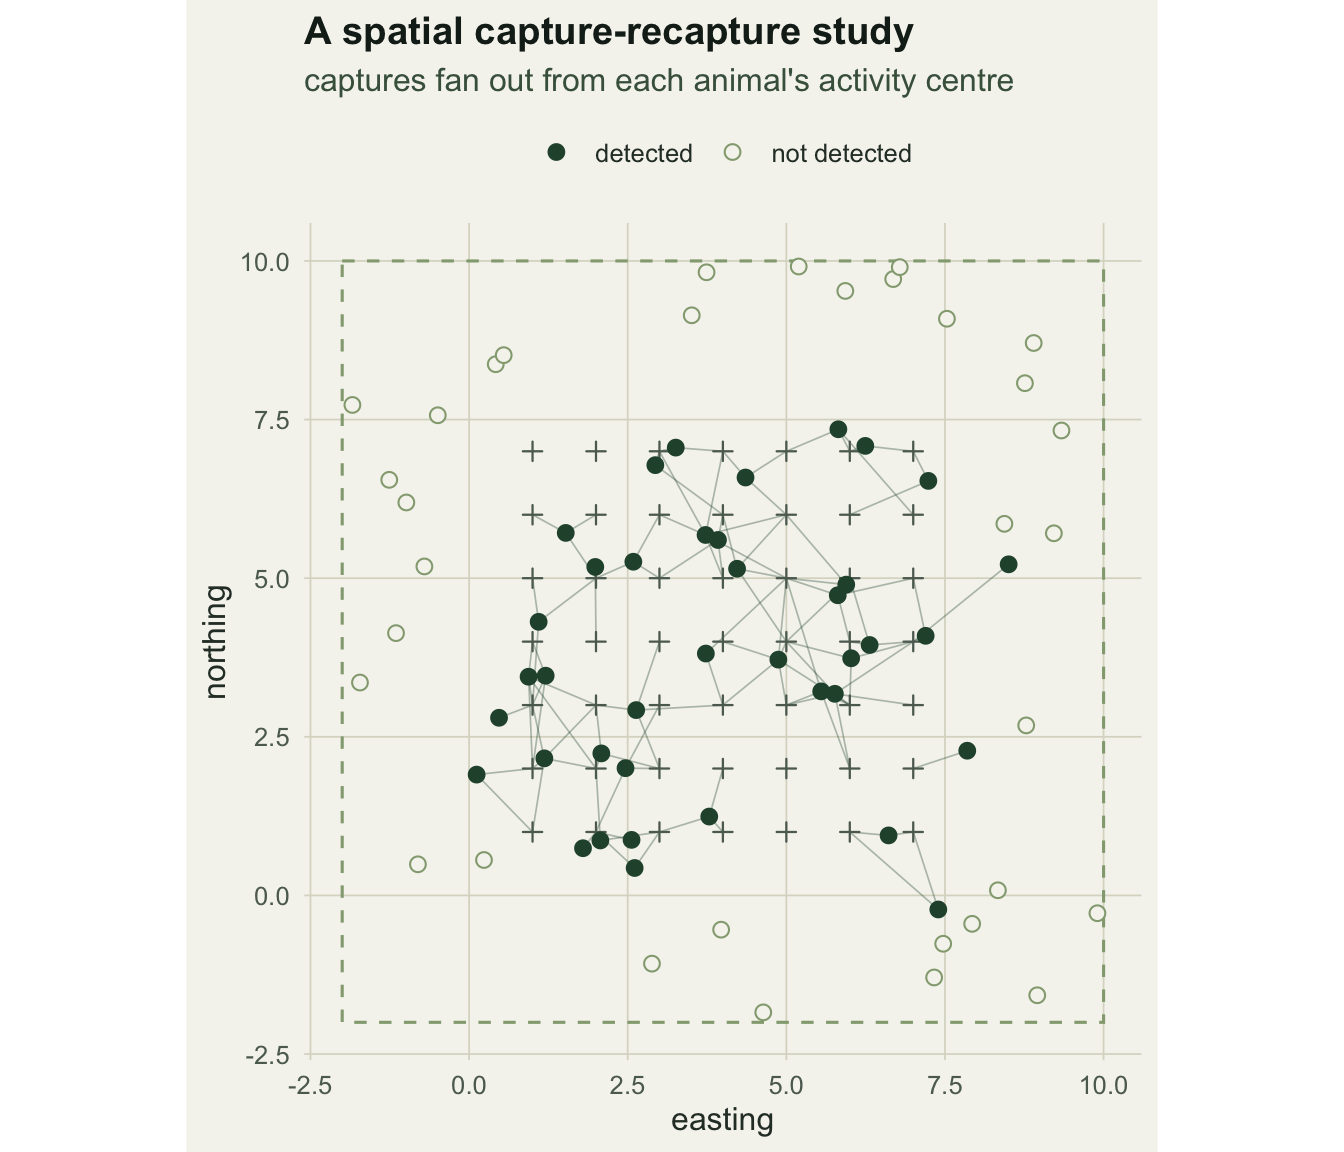
image-alt: "Trap grid with animal activity centres and thin links from each centre to the traps where the animal was detected."
---
*Corrected 7 October 2026: the text said that none of the buffer widths was more correct than another, although one of them lands near the true density; it now says that nothing in the non-spatial analysis tells you which buffer to use, and that only the known truth shows which one comes close.*
*Corrected 30 September 2026: the integration grid ran through the edges of the state-space, which understated the effective sampling area and overstated density; the grid now uses cell centres, and the density and effective-area estimates are updated.*
A closed-population capture-recapture study gives you an abundance estimate: how many marked individuals were in the sampled population. Turn that into a density (animals per unit area) and a problem appears at once. Density is abundance divided by area, but which area? The trap array covers one region; the animals it catches range over a larger, fuzzy one, because an individual whose home range only clips the edge of the array can still be caught. The effective area sampled is unknown, and it depends on how far animals move relative to the trap spacing.
Spatial capture-recapture (SCR) removes the guesswork. It uses *where* each animal was caught, not just *whether*, and models detection as a function of the distance between a trap and the animal's latent activity centre. Density becomes an explicit parameter. This post builds the SCR likelihood from scratch in base R (integrating the unknown activity centres over a grid), and shows why the non-spatial route to density has no non-arbitrary answer.
## The edge-effect problem
Picture an animal with a home range centred at some point `s`. If `s` sits over the array, the animal is caught often; if `s` sits just outside, it is caught occasionally; far outside, never. A conventional estimator of N counts the animals exposed to the traps, a group with no crisp boundary. Efford (2004) put it plainly: closed-population statistics carry an unknown bias from edge effects that varies with the trap layout and the home-range size. The average distance between an individual's successive captures does track movement scale, but it is itself a function of trap spacing and grid extent, so it does not fix the problem on its own.
SCR treats each animal's activity centre as a latent variable with a spatial prior over a state-space, and models the per-occasion detection probability at trap `j` for an animal centred at `s` with a half-normal function:
$$p_j(s) = g_0 \, \exp\!\left(-\frac{d(s, x_j)^2}{2\sigma^2}\right),$$
where `g0` is the baseline detection at the centre, `sigma` is the spatial scale of detection (bigger home ranges give a bigger sigma), and `d` is the distance from `s` to trap `x_j`. Density `D` enters through the point process for activity centres, so the estimate does not lean on any hand-drawn buffer.
## A simulated trapping study
We lay out a 7 by 7 grid of traps at unit spacing, run six occasions, and place `N_true` activity centres uniformly across a state-space that extends a buffer beyond the array. Detection at each trap on each occasion is a Bernoulli draw with the half-normal probability above.
```{r}
#| label: setup
#| code-fold: true
#| code-summary: "Setup: packages, colours and plot theme"
#| results: hide
#| message: false
#| warning: false
library(ggplot2)
paper <- "#f5f4ee"; ink <- "#16241d"; body <- "#2c3a31"; forest <- "#275139"
labelc <- "#46604a"; sage <- "#93a87f"; linec <- "#dad9ca"; faint <- "#5d6b61"
gold <- "#c9b458"; rust <- "#b5534e"
theme_te <- function(base_size = 12) {
  theme_minimal(base_size = base_size) +
    theme(
      plot.background  = element_rect(fill = paper, colour = NA),
      panel.background = element_rect(fill = paper, colour = NA),
      panel.grid.minor = element_blank(),
      panel.grid.major = element_line(colour = linec, linewidth = 0.3),
      axis.title = element_text(colour = body),
      axis.text  = element_text(colour = faint),
      plot.title = element_text(colour = ink, face = "bold"),
      plot.subtitle = element_text(colour = labelc),
      legend.title = element_text(colour = body),
      legend.text  = element_text(colour = body),
      strip.text   = element_text(colour = ink)
    )
}
```
```{r}
#| label: simulate
set.seed(0)
spacing  <- 1
tr       <- seq(1, 7, by = spacing)              # 7 x 7 = 49 traps
traps    <- as.matrix(expand.grid(x = tr, y = tr))
J        <- nrow(traps)
K        <- 6                                    # occasions
g0_true  <- 0.30
sig_true <- 0.70
buffer   <- 3
xl <- range(traps[, 1]) + c(-buffer, buffer)     # state-space extent
yl <- range(traps[, 2]) + c(-buffer, buffer)
A  <- diff(xl) * diff(yl)                         # state-space area
N_true <- 72
D_true <- N_true / A                              # animals per unit area

# activity centres and occasion-level encounters
sx <- runif(N_true, xl[1], xl[2])
sy <- runif(N_true, yl[1], yl[2])
d_it <- sqrt(outer(sx, traps[, 1], "-")^2 + outer(sy, traps[, 2], "-")^2)
p_it <- g0_true * exp(-d_it^2 / (2 * sig_true^2))
y_arr <- array(rbinom(N_true * J * K, 1, rep(p_it, times = K)),
               dim = c(N_true, J, K))
y_ij  <- apply(y_arr, c(1, 2), sum)               # per-trap binomial(K,.) counts
caught <- rowSums(y_ij) > 0
n      <- sum(caught)
Y      <- y_ij[caught, , drop = FALSE]            # detected individuals
sxc    <- sx[caught]; syc <- sy[caught]

tot_det    <- sum(Y)
traps_per  <- rowSums(Y > 0)
spat_recap <- sum(traps_per >= 2)                 # caught at 2 or more traps
```
Of the `r N_true` animals in the state-space, `r n` were detected at least once, giving `r tot_det` trap-level detections. The information SCR relies on is the spatial spread: `r spat_recap` animals were caught at two or more traps. Those spatial recaptures are what pin down sigma; an animal seen at a single trap tells you little about how far it ranges.
## The SCR likelihood by integrating over activity centres
Each animal's centre is unknown, so we integrate it out. Lay a fine grid over the state-space; for a centre at grid cell `g`, the probability of a capture history is a product of binomials across traps, and the probability of being detected at all is one minus the probability of no detection anywhere. Averaging the detection probability over the cell centres gives `pbar`, and the effective sampling area is the state-space area times `pbar`. (Centres rather than a lattice through the boundaries: boundary points stand for cells that overhang the edge, so their plain average would understate the effective area and overstate density.)
Under a Poisson point process for centres with intensity `D`, the number detected is Poisson with mean `D` times the effective area, and each detected animal contributes its capture-history probability marginalised over the grid. We maximise over `log D`, `qlogis(g0)` and `log sigma`.
```{r}
#| label: fit
hx <- diff(xl) / 40; hy <- diff(yl) / 40          # 40 x 40 equal cells
gx <- seq(xl[1] + hx / 2, xl[2] - hx / 2, length.out = 40)   # cell centres
gy <- seq(yl[1] + hy / 2, yl[2] - hy / 2, length.out = 40)
G  <- as.matrix(expand.grid(x = gx, y = gy))
dG <- sqrt(outer(G[, 1], traps[, 1], "-")^2 + outer(G[, 2], traps[, 2], "-")^2)

negll <- function(theta) {
  D  <- exp(theta[1]); g0 <- plogis(theta[2]); sg <- exp(theta[3])
  P  <- g0 * exp(-dG^2 / (2 * sg^2))              # detection prob, grid x trap
  pdot <- 1 - exp(rowSums(K * log1p(-P)))          # P(detected | centre at g)
  pbar <- mean(pdot)
  if (pbar <= 0) return(1e10)
  lb <- matrix(0, n, nrow(G))                      # log capture-history prob per grid cell
  for (j in 1:J)
    lb <- lb + outer(Y[, j], P[, j], function(y, p) dbinom(y, K, p, log = TRUE))
  m    <- apply(lb, 1, max)
  logf <- m + log(rowMeans(exp(lb - m)))           # marginal over the grid
  -(dpois(n, D * A * pbar, log = TRUE) + sum(logf) - n * log(pbar))
}

st  <- c(log(n / (A * 0.4)), qlogis(0.2), log(1))
fit <- optim(st, negll, method = "BFGS", hessian = TRUE,
             control = list(maxit = 500, reltol = 1e-10))
stopifnot(fit$convergence == 0)   # check before inverting the Hessian
D_hat   <- exp(fit$par[1]); g0_hat <- plogis(fit$par[2]); sig_hat <- exp(fit$par[3])
V       <- solve(fit$hessian)
se_logD <- sqrt(V[1, 1])
D_lo <- exp(fit$par[1] - 1.96 * se_logD); D_hi <- exp(fit$par[1] + 1.96 * se_logD)
se_g0  <- sqrt(V[2, 2]) * g0_hat * (1 - g0_hat)
se_sig <- sqrt(V[3, 3]) * sig_hat

Ph       <- g0_hat * exp(-dG^2 / (2 * sig_hat^2))
pdh      <- 1 - exp(rowSums(K * log1p(-Ph)))
pbar_hat <- mean(pdh)
a_eff    <- A * pbar_hat
N_hat    <- D_hat * A
```
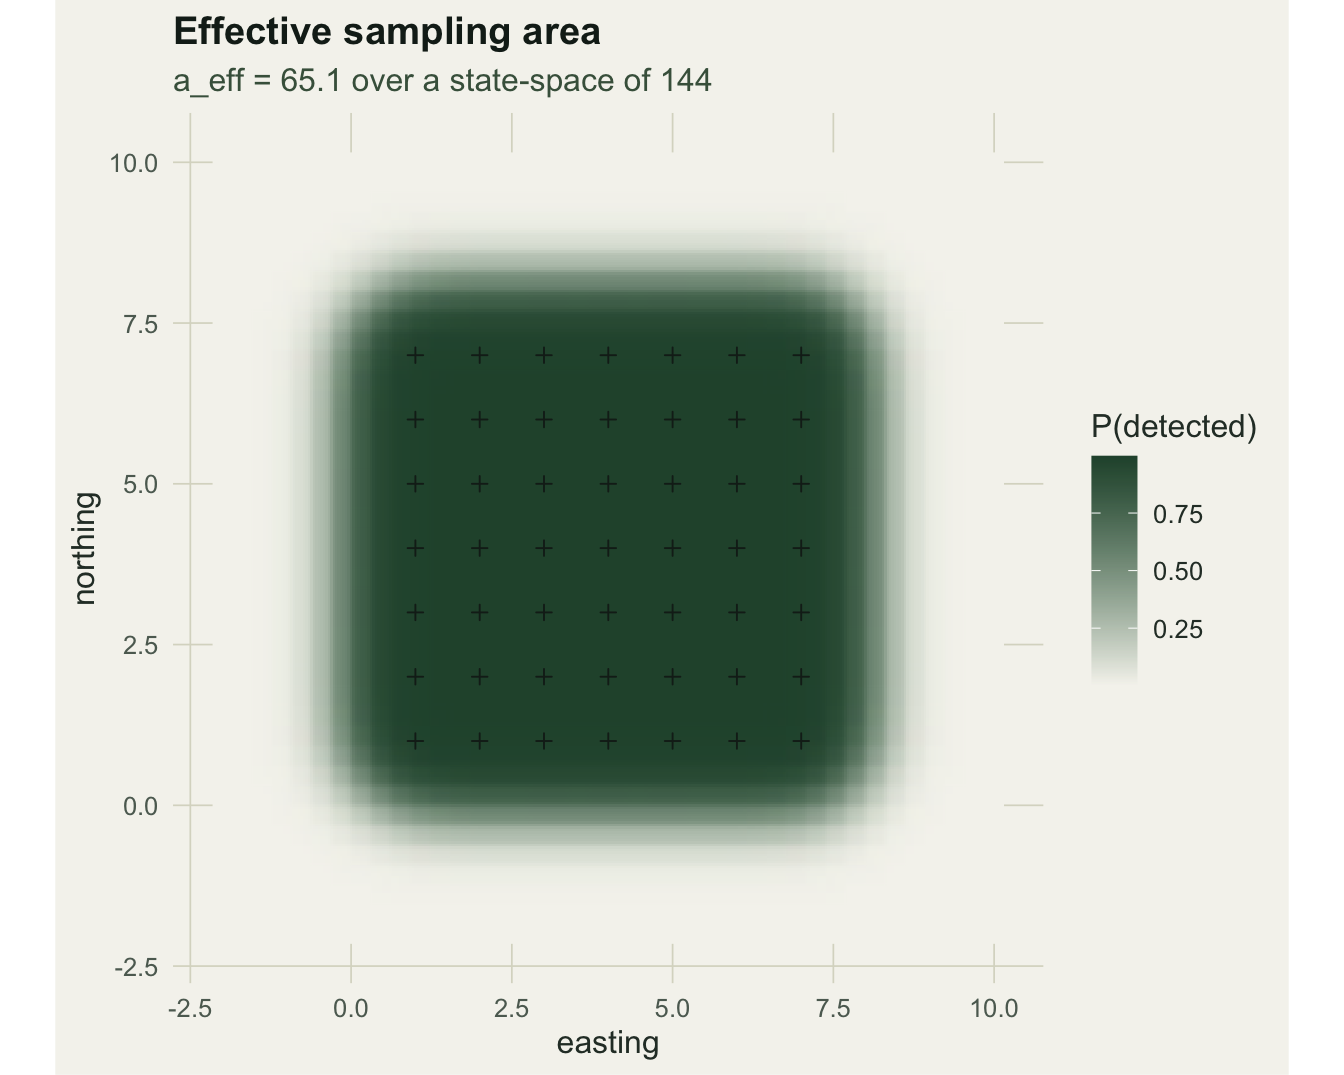
The fit recovers the detection parameters: `g0_hat` is `r round(g0_hat, 3)` (SE `r round(se_g0, 3)`, true `r g0_true`) and `sigma_hat` is `r round(sig_hat, 3)` (SE `r round(se_sig, 3)`, true `r sig_true`). Density comes out at `r round(D_hat, 3)` animals per unit area, with a 95% interval of [`r round(D_lo, 3)`, `r round(D_hi, 3)`] that covers the true `r round(D_true, 3)`. The point estimate sits a little above truth in this single realisation, which is normal: density from `r n` animals and `r spat_recap` spatial recaptures carries real uncertainty (a later post in this series, [SCR sampling design and precision](../scr-sampling-design/), takes up how the array design controls that precision). The effective sampling area is `r round(a_eff, 1)`, well below the state-space area of `r A`, because animals near the edge of the state-space are rarely caught. That effective area is estimated, not chosen.
## Why the non-spatial route cannot give a density
Fit a plain closed-population M0 model to the same data (collapse the traps, so an animal is either caught or not on each occasion) and profile the likelihood over integer N.
```{r}
#| label: naive
anyk  <- apply(y_arr, c(1, 3), function(z) as.integer(any(z > 0)))
freqK <- rowSums(anyk)[caught]                     # occasions caught, per animal
Ttot  <- sum(freqK)
Ng    <- n:600
m0ll  <- sapply(Ng, function(N) {
  p <- Ttot / (N * K)
  if (p <= 0 || p >= 1) return(-Inf)
  lchoose(N, n) + Ttot * log(p) + (N * K - Ttot) * log(1 - p)
})
N0_hat <- Ng[which.max(m0ll)]
p0_hat <- Ttot / (N0_hat * K)

arr_span   <- apply(traps, 2, function(z) diff(range(z)))        # 6 by 6 array
array_area <- prod(arr_span)                                     # 36
bw         <- c(1, 2, 3, 4)                                      # buffer widths in sigma
buff_area  <- sapply(bw, function(w) prod(arr_span + 2 * w * sig_true))
D_arr      <- N0_hat / array_area
D_buf      <- N0_hat / buff_area
```
The non-spatial model estimates `r N0_hat` animals exposed to the array, which is exactly the `r n` animals actually caught: with detection this high the M0 likelihood peaks at the boundary and adds no unseen individuals, which is already a warning about what this model can say. To make that a density you divide by an area, and there is the trap: the array footprint alone gives `r round(D_arr, 2)` per unit area (`r round(D_arr / D_true, 1)` times the truth), while buffering the array by one, two, three or four sigma gives `r round(D_buf[1], 3)`, `r round(D_buf[2], 3)`, `r round(D_buf[3], 3)` and `r round(D_buf[4], 3)`. That is a `r round(max(c(D_arr, D_buf)) / min(D_buf), 1)`-fold range, driven entirely by an arbitrary choice of buffer width. Nothing in the non-spatial analysis says which of these buffers to use. The two-sigma buffer happens to land near the truth here, which only the known truth reveals, and every buffer was built from the true sigma, which a field study does not have; the older literature added such buffers on heuristic grounds precisely because the effective area was unknown (Royle and Young 2008). SCR sidesteps the choice: density is `r round(D_hat, 3)` directly, with the effective area of `r round(a_eff, 1)` falling out of the model.
```{r}
#| label: fig-array
#| fig-cap: "Trap grid (crosses), true activity centres (filled where detected, hollow where not), the state-space boundary (dashed), and links from each detected centre to the traps where it was caught. The spatial spread of an animal's captures carries the movement information SCR uses."
#| fig-alt: "A 7 by 7 grid of trap crosses on a pale panel; green filled dots mark detected animals with thin lines fanning out to the traps that caught them, hollow dots mark undetected animals near the edges, and a dashed rectangle shows the wider state-space."
#| fig-width: 7
#| fig-height: 6
seg <- do.call(rbind, lapply(which(caught), function(i) {
  ii <- match(i, which(caught)); js <- which(Y[ii, ] > 0)
  data.frame(x = sxc[ii], y = syc[ii], xend = traps[js, 1], yend = traps[js, 2])
}))
cd <- data.frame(x = sx, y = sy, det = ifelse(caught, "detected", "not detected"))
p1 <- ggplot() +
  annotate("rect", xmin = xl[1], xmax = xl[2], ymin = yl[1], ymax = yl[2],
           fill = NA, colour = sage, linetype = "dashed") +
  geom_segment(data = seg, aes(x, y, xend = xend, yend = yend),
               colour = forest, alpha = 0.35, linewidth = 0.3) +
  geom_point(data = as.data.frame(traps), aes(x, y), shape = 3,
             colour = faint, size = 2, stroke = 0.6) +
  geom_point(data = cd, aes(x, y, shape = det, colour = det, fill = det), size = 2.4) +
  scale_shape_manual(values = c(detected = 21, "not detected" = 21)) +
  scale_colour_manual(values = c(detected = forest, "not detected" = sage)) +
  scale_fill_manual(values = c(detected = forest, "not detected" = paper)) +
  coord_equal() +
  labs(x = "easting", y = "northing", shape = NULL, colour = NULL, fill = NULL,
       title = "A spatial capture-recapture study",
       subtitle = "captures fan out from each animal's activity centre") +
  theme_te() + theme(legend.position = "top")
p1
```
The detection surface below shows the estimated probability that an animal centred at each point is caught at all. Its total is the effective sampling area: the array reaches beyond its own footprint but fades within a few sigma, which is exactly the region a fixed buffer tries, and fails, to guess.
```{r}
#| label: fig-pdot
#| fig-cap: "Estimated probability of detection as a function of an animal's activity-centre location (paper to forest gradient), with traps overlaid. The integral of this surface is the effective sampling area; it extends past the array but decays smoothly, so no single buffer width reproduces it."
#| fig-alt: "A smooth heatmap over the state-space shading from pale to dark green, darkest across the trap grid and fading outward, with small dark crosses marking the traps."
#| fig-width: 7
#| fig-height: 5.6
gdf <- data.frame(x = G[, 1], y = G[, 2], pdot = pdh)
p2 <- ggplot(gdf, aes(x, y, fill = pdot)) +
  geom_raster(interpolate = TRUE) +
  geom_point(data = as.data.frame(traps), aes(x, y), inherit.aes = FALSE,
             shape = 3, colour = ink, size = 1.6, stroke = 0.5) +
  scale_fill_gradient(low = paper, high = forest, name = "P(detected)") +
  coord_equal() +
  labs(x = "easting", y = "northing",
       title = "Effective sampling area",
       subtitle = paste0("a_eff = ", round(a_eff, 1), " over a state-space of ", A)) +
  theme_te()
p2
```
## Takeaways
Non-spatial capture-recapture answers a question with no clean edge: how many animals were exposed to the array. Converting that to density needs an area that the data do not define, and the answer swings several-fold with the buffer you pick. SCR makes the activity centre a latent variable, ties detection to distance through `g0` and `sigma`, and estimates density directly with a principled effective sampling area. The whole likelihood is a grid integral and an `optim` call; no specialised package is needed to see how it works. The spatial recaptures do the heavy lifting, so a later post in this series looks at how trap spacing and array extent govern whether sigma, and therefore density, can be estimated with any precision.
```{r}
#| label: thumb
#| include: false
ggsave("thumbnail.png", p1 + labs(title = NULL, subtitle = NULL) +
theme(legend.position = "none"),
width = 7.5, height = 5.4, dpi = 100, bg = paper)
```
## References
Efford, M. 2004. Oikos 106(3):598-610 (10.1111/j.0030-1299.2004.13043.x).
Borchers, D. L. and Efford, M. G. 2008. Biometrics 64(2):377-385 (10.1111/j.1541-0420.2007.00927.x).
Efford, M. G., Borchers, D. L. and Byrom, A. E. 2009. In: Modeling Demographic Processes in Marked Populations, Springer (10.1007/978-0-387-78151-8_11).
Royle, J. A. and Young, K. V. 2008. Ecology 89(8):2281-2289 (10.1890/07-0601.1).
Otis, D. L., Burnham, K. P., White, G. C. and Anderson, D. R. 1978. Wildlife Monographs 62:3-135.
Royle, J. A., Chandler, R. B., Sollmann, R. and Gardner, B. 2014. Spatial Capture-Recapture. Academic Press (ISBN 978-0-12-405939-9).
## Related tutorials
- [Spatial capture-recapture on a meandering stream](../spatial-capture-recapture-on-a-stream-network/)
- [Bayesian spatial capture-recapture](../bayesian-spatial-capture-recapture/)
- [SCR sampling design and precision](../scr-sampling-design/)
- [Detection covariates and checking in SCR](../scr-detection-covariates/)